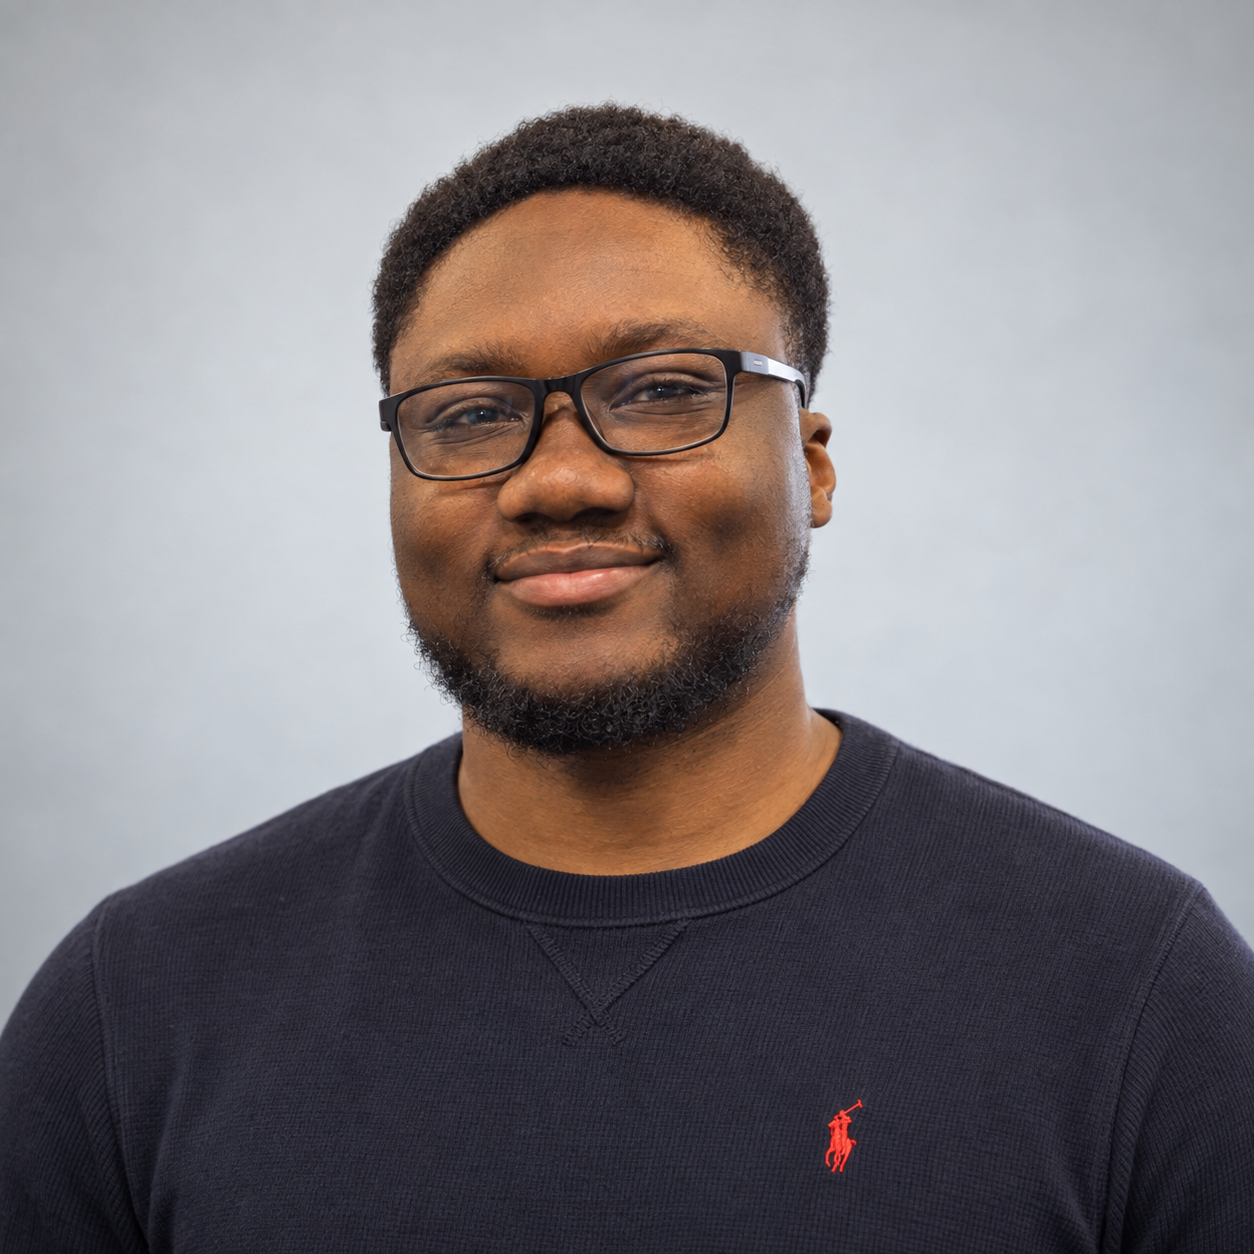
PhD Candidate @ IASL · GWU
I develop safe AI-based control systems for multi-agent aircraft both manned and unmanned, especially when sensing fails.
My work spans robust multi-agent reinforcement learning, safety filtering in learned control policies, and language models in the control loop. Next: world (action) models for multi-agent planning.
selected work
Robust Multi-Agent Reinforcement Learning for Small UAS Separation Assurance under GPS Degradation and Spoofing
IEEE Conference on Decision and Control (CDC) 2026 · to appear
Runtime Safety Filtering for Learned Small UAS Separation Policies under GNSS Degradation
Digital Avionics Systems Conference (DASC) 2026 · presented · proceedings forthcoming
- 3rd Best of Conference
- Best in Track
- Best in Session
Fine-Tuning Large Language Models for Cooperative Tactical Deconfliction of Small Unmanned Aerial Systems
3rd Workshop on Multi-Agent Embodied Intelligent Systems Meet Agentic-AI era: Opportunities, Challenges and Futures (MEIS@CVPR 2026)
eVTOL Aircraft Energy Consumption Estimation with Conflict Resolution in High-Density Airspaces
Integrated Communications Navigation, and Surveillance (ICNS) Conference
- Best in Session
about me
I am a PhD candidate in Mechanical and Aerospace Engineering at The George Washington University, advised by Prof. Peng Wei in the Intelligent Aerospace Systems Lab (IASL). In Summer 2026 I was a Visiting Researcher at UC Berkeley (CITRIS and the Banatao Institute) with Prof. Alexandre Bayen, working on multi-modal aircraft trajectory prediction.
My research asks how learned decision-makers, such as reinforcement learning policies and language models, can be trusted in dense, safety-critical multi-agent systems. I work on separation assurance for drones and advanced air mobility, with theory (adversarial robustness bounds), algorithms (multi-agent RL and runtime safety filters), and closed-loop evaluation in air traffic simulation.
Before GWU, I earned a master’s in Control Science and Engineering at Tsinghua University, where I worked on reinforcement learning for fault-tolerant flight control, and a B.S. in Aircraft Design and Engineering at Beihang University (BUAA), after earlier studies at National Cheng Kung University. Full details are in my CV.
research themes
Robust multi-agent RL under degraded sensing
Separation policies for dense drone and aircraft traffic that stay safe when GPS/GNSS position reports are noisy, delayed, or spoofed.
Runtime safety for learned policies
Filters that sit around a deployed policy, without retraining it, and correct what it sees or what it does when inputs cannot be trusted.
Foundation models in the control loop
Language models as decision-makers and advisors for air traffic and maritime collision avoidance, with fine-tuning, fallback control, and closed-loop evaluation.
news
Oct 2026
Sep 2026
Sep 2026
Sep 2026
Jul 2026
Jun 2026
Earlier news
May 2026
May 2026
Apr 2026
Dec 2025
Jan 2025
Sep 2024
Aug 2024
Aug 2024
May 2024
service
Reviewer. Journals: Journal of Guidance, Control, and Dynamics; IEEE Transactions on Aerospace and Electronic Systems; IEEE Transactions on Intelligent Transportation Systems; Transportation Research Part C; Journal of Aerospace Information Systems; Engineering Applications of Artificial Intelligence. Conferences: IEEE CDC, IEEE ITSC, AAAI, ICRA, ICGNC.
Organizing. Hosted the 2024 Safe and Responsible AI workshop at GWU, with speakers from the FAA, Johns Hopkins APL, MIT Lincoln Laboratory, and NIST.
affiliations & research support
Doctoral research
 George Washington University
Mechanical & Aerospace Engineering · IASL
Visiting research · Summer 2026
 UC Berkeley
CITRIS and the Banatao Institute
Research support
 NASA
University Leadership Initiative
For research collaborations or internship opportunities, reach out by email.